
Nicholas Petersen, PhD in Mechanical Engineering-Engineering Mechanics, 2026
Throughout my journey into research here at Michigan Tech, I have explored how vehicle motion control is applied to electric vehicles. Electric vehicle powertrains have a number of advantages over their Internal Combustion Engine-powered counterparts, including precise low speed torque control and packaging flexibility. My research focuses on leveraging electric vehicles to improve vehicle ride comfort and safety.
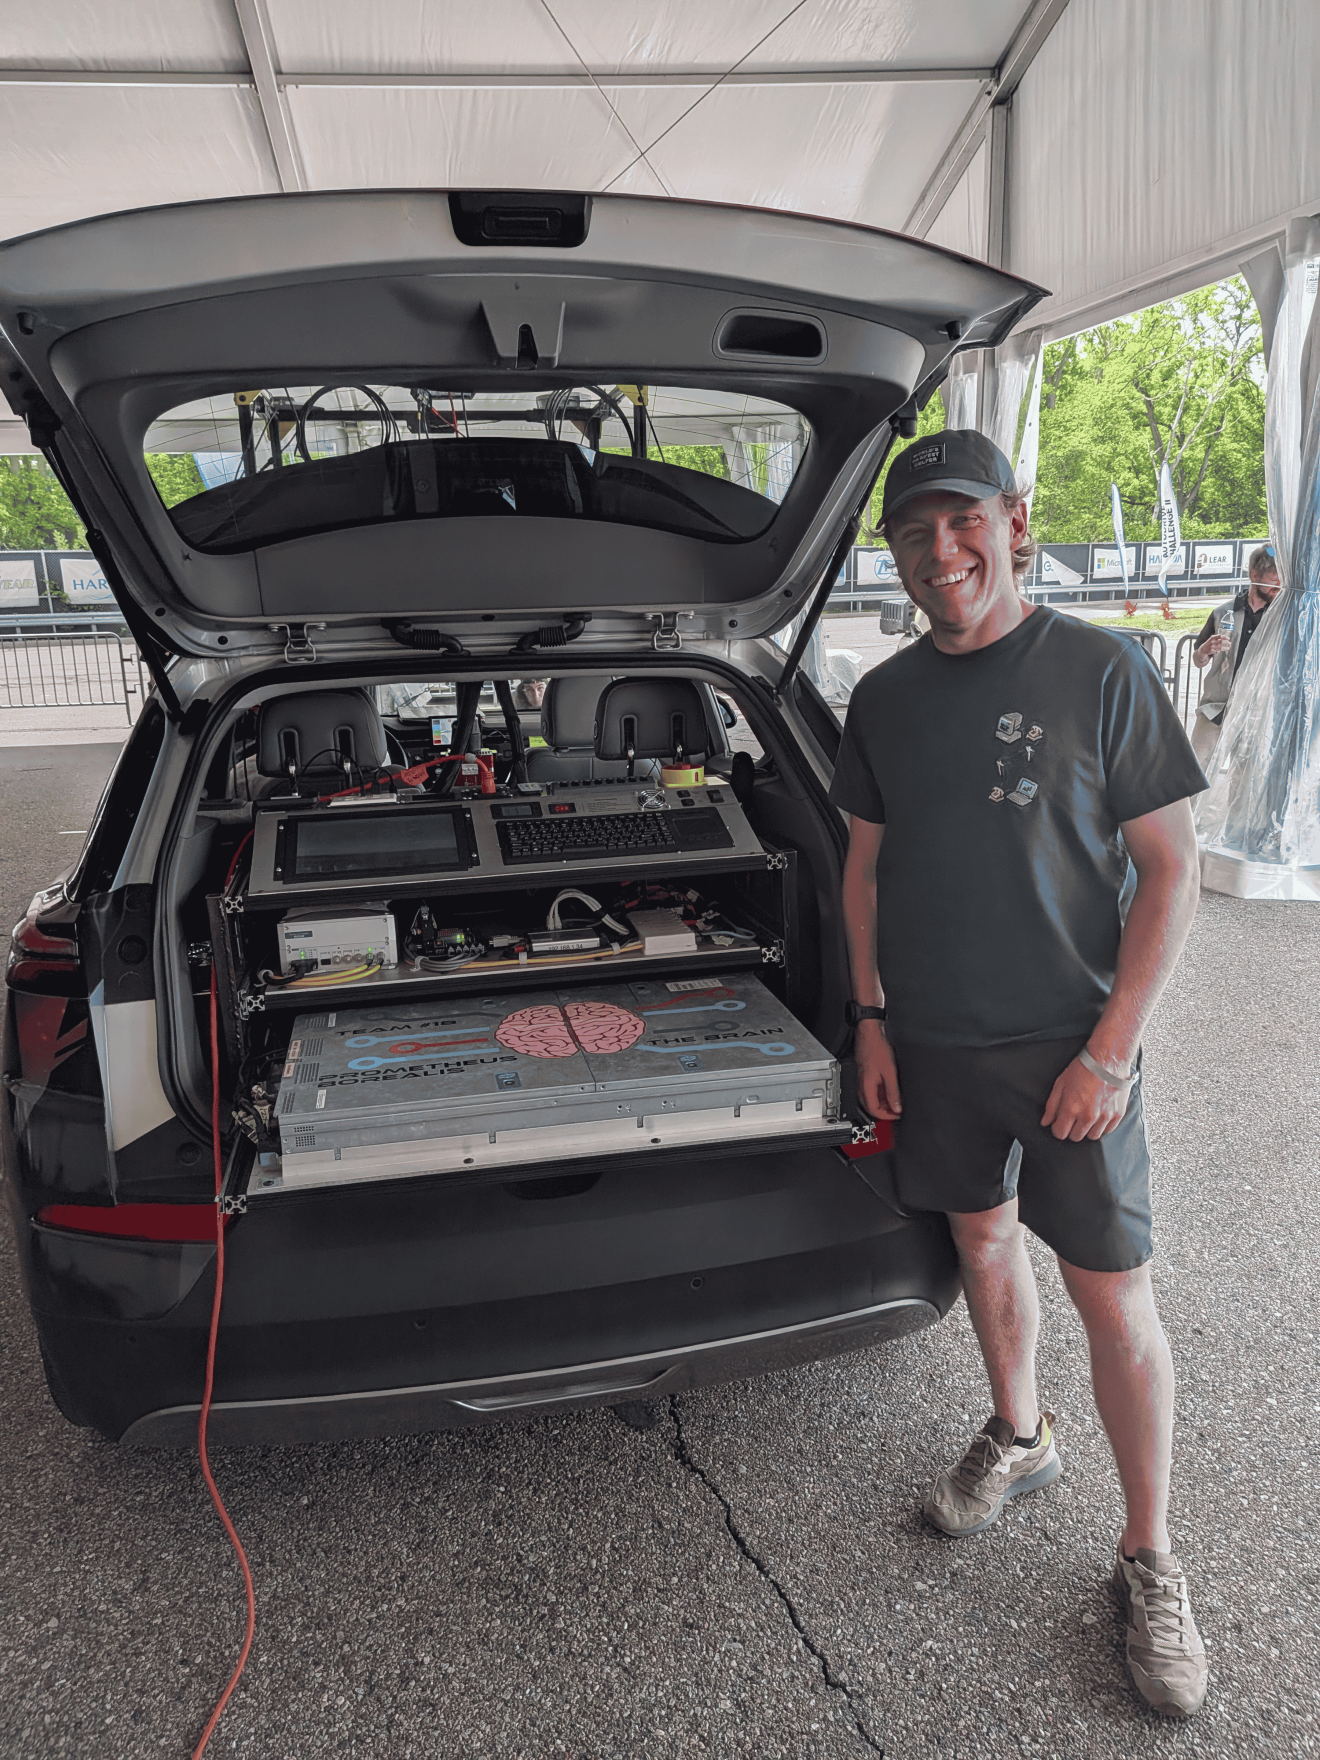
The majority of my time pursuing my PhD, I have supported the Robotic Systems Enterprise as a graduate research assistant. The primary project of this enterprise involved designing a level 4 autonomous vehicle for the General Motors SAE AutoDrive Challenge. Through mentoring teams of undergraduate students, I have gained valuable leadership experience and technical skills. Developing an autonomous electric vehicle has also created opportunities for research. Using the 2023 Chevrolet Bolt EUV AV, I designed and tested a robust low speed sliding mode torque controller to maintain velocity tracking on high grades and rough roads.
Some modern electric vehicles feature independent electric motors for each wheel. I explore how sliding mode control can exploit independent torque control to re-stabilize a vehicle after a sideswipe collision. I show how sliding mode control can be applied to a two wheel rear drive vehicle for re-stabilization of a range of collision geometries. I also show that this control system can be implemented on a physical scale vehicle.
I would like to thank the Graduate Dean Awards Advisory Panel for selecting me to receive the Finishing Fellowship this fall. I’m also grateful to my advisor Dr. Darrell Robinette for the guidance throughout my PhD. My time working with my friends in the lab, as well as the opportunities Michigan Tech has provided, has shaped me into the researcher I am today.